

€ 218,07 Gratis verzending

Uitgelicht
|
|
218,07 |
Naar shop
|
| VERGELIJK ALLE AANBIEDERS (1) | ||
 Beschrijving
Vergelijk aanbieders (1)
€ 218,07 Gratis verzending
Winkels met andere maten
Beschrijving
(1)
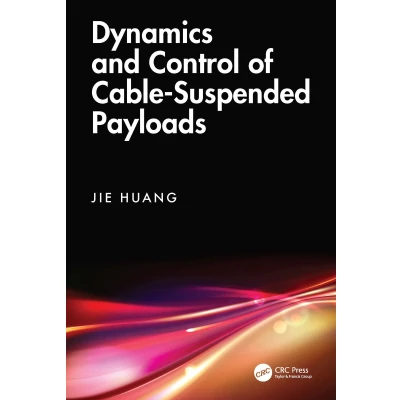
This book provides a thorough overview of the theoretical principles of nonlinear dynamics and vibration control for large, heavy cable-suspended payloads transported by industrial cranes. It addresses the complex swing and twisting phenomena caused by crane movement commands that lead to dangerous vibrations. This book provides a thorough overview of the theoretical principles of nonlinear dynamics and vibration control for large, heavy cable-suspended payloads transported by industrial cranes. It addresses the complex swing and twisting phenomena caused by crane movement commands that lead to dangerous vibrations. This book first systematically explores the theoretical domains of nonlinear dynamics and vibration control. Chapter 1 on nonlinear dynamics covers dynamic modeling of nonlinear systems, analysis of nonlinear oscillators, approximate solutions, modal analysis of multiple-mode systems, and Lyapunov stability. Chapter 2 on vibration control examines linear control, nonlinear control, intelligent control, input shapers, and command smoothers—all of which are proven effective and robust methods for attenuating vibrations. The subsequent chapters illustrate these frameworks through industrial applications involving bridge cranes, tower and boom cranes, quadcopter slung loads, helicopter slung loads, and twin-lift cranes. Due to the complex nonlinear dynamic behavior of cable-suspended payloads, the book addresses significant challenges in dynamic modeling and analysis, providing practical solutions for reducing vibrations. It provides advanced control methods and vibration-reduction solutions for cable-suspended payloads and serves researchers and graduate students working in this field.
 Productspecificaties
| EAN |
|
|---|---|
| Maat |
|
 Prijshistorie
Prijzen voor het laatst bijgewerkt op:
 Gerelateerde resultaten


